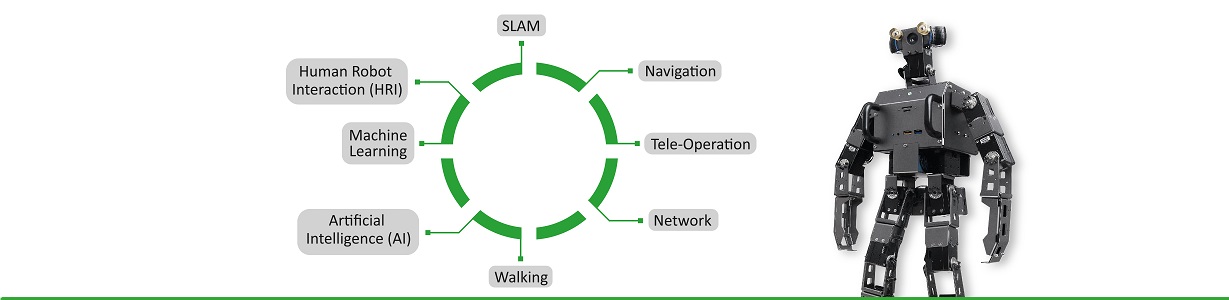
I am working with a Unitree R1 EDU. On the Jetson, we are only receiving a single camera feed (1280×720) via /frontvideostream and the video hub (API 1001). You recommend using stereo VSLAM with the binocular camera; how can we access both camera feeds (left and right), or a depth map, on the development computer? Is there a different topic, a different API, or a firmware setting for this?